Use cases Robotics
A robot's parts, signals and modes in one model
For robotics engineers whose mechanical, electrical, firmware and autonomy decisions are made in parallel and meet for the first time on the bench. Cairn keeps one model of the robot: its subsystems, the signals between them, the modes it runs in and how it gets out of a fault, with the requirements and tests tied to each.
The problem
A robot is a drivetrain, sensors, compute, power and software that all have to agree. The motor controller expects a velocity command at one rate and the planner sends it at another; the e-stop is wired one way and written up another.
The modes are the hardest part to keep straight: what the robot does at power-up, when a sensor drops out, after an e-stop, and what has to be true before it moves again. Written as prose, nobody can check that every fault has a way out.
A workflow in Cairn
Break the robot down
Describe the robot and its job, and let the Architect propose the subsystems: say navigation, power, drivetrain and payload. Review each in Change Review, then go deeper on the ones that carry the risk, such as the motor controller.
System decomposition →Pin down the signals
Give each interface its signals, with direction, rate and data type: a velocity command from the nav computer to the motor controller, wheel speed coming back. The N² chart shows any subsystem nothing talks to.
Architecture and interfaces →Model the modes as a state machine
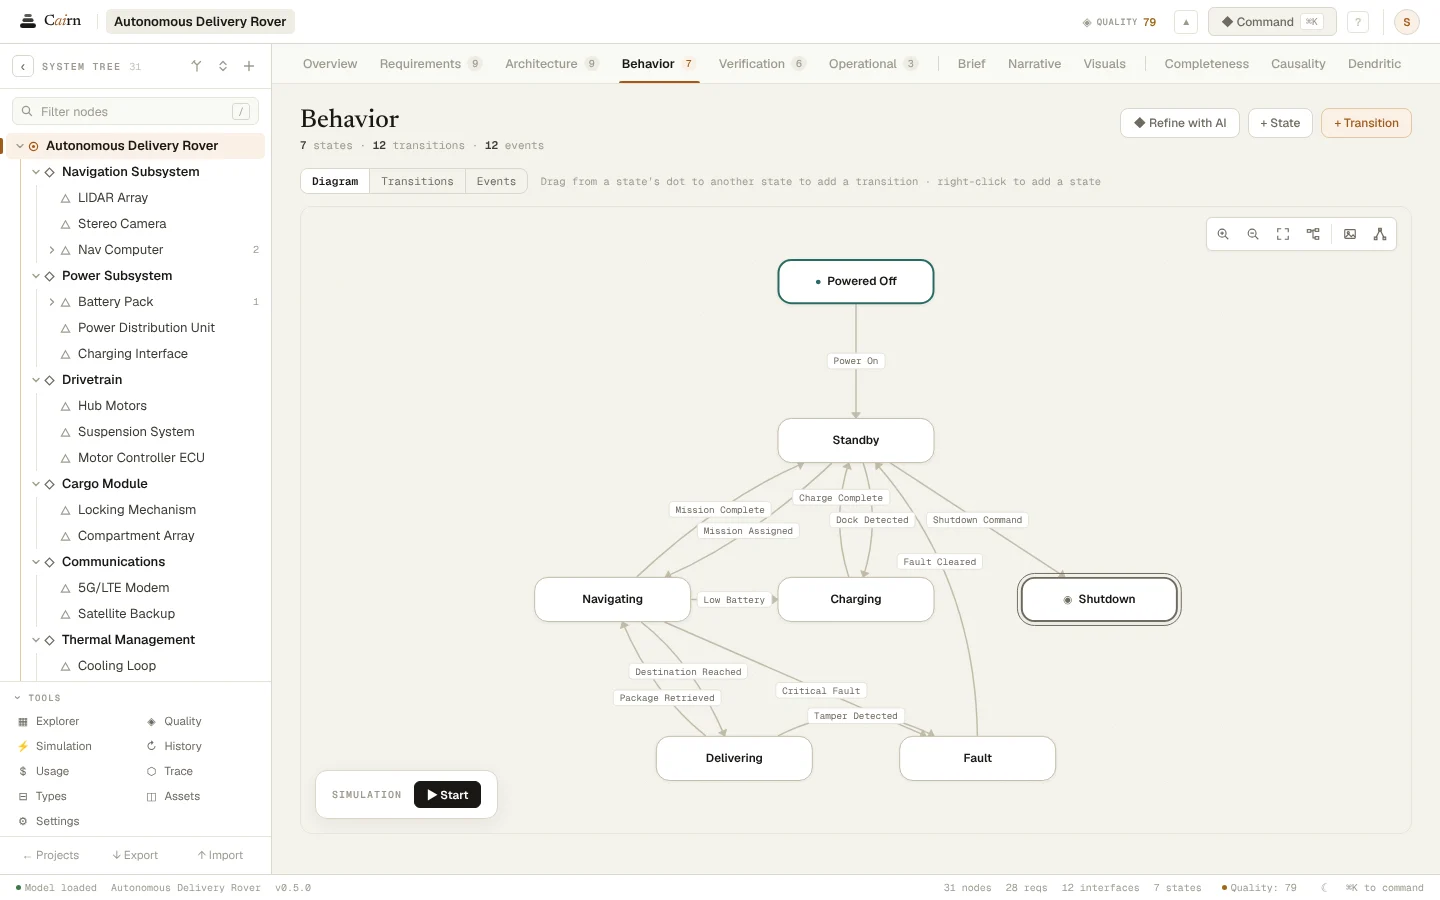
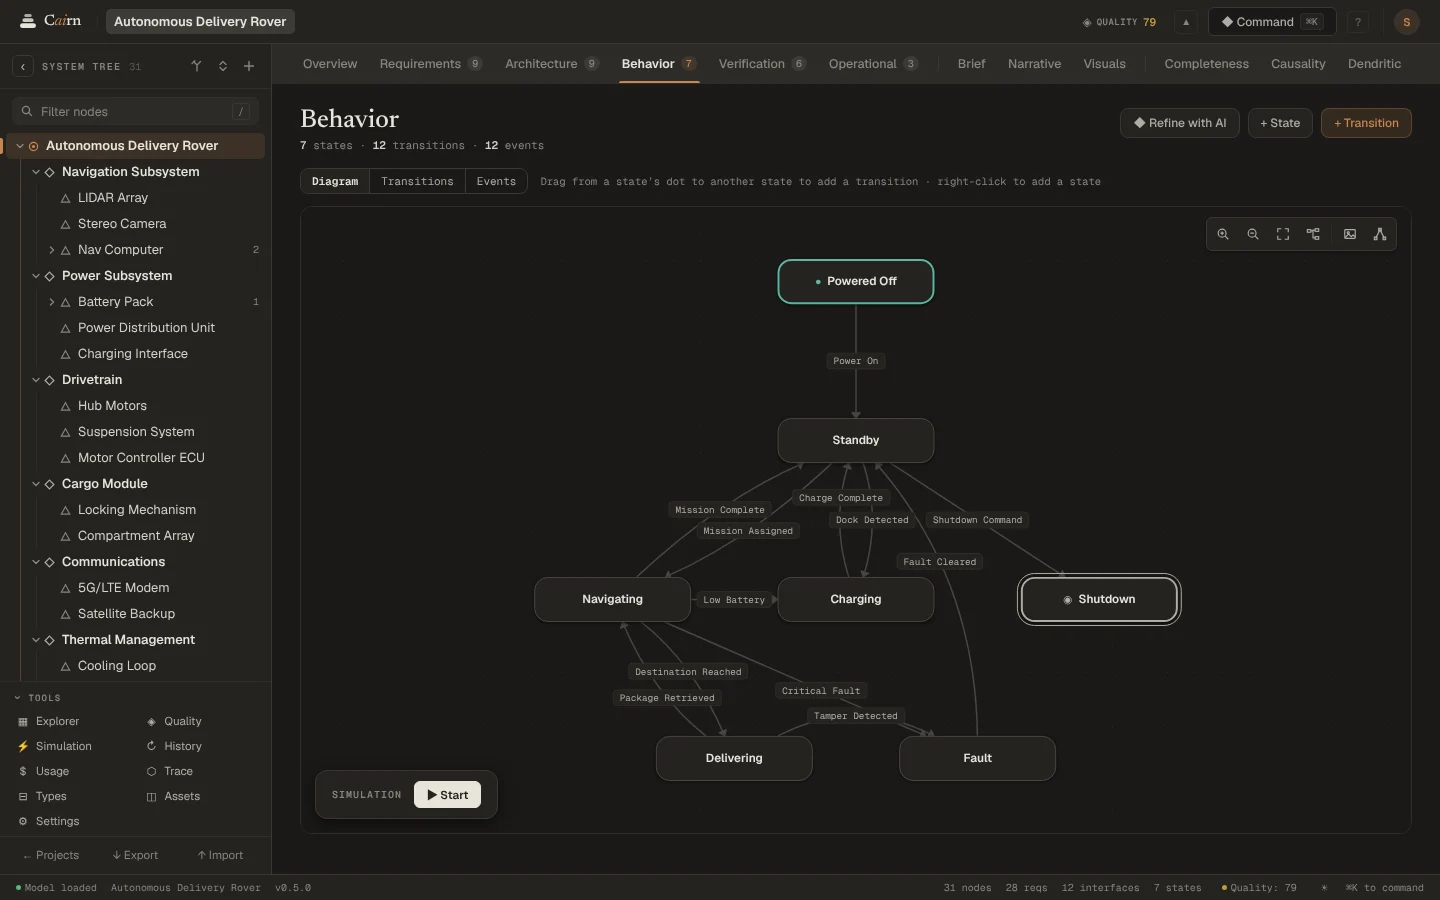
Draw the states the robot runs in, from Powered Off through Standby and Navigating to Fault, with the trigger, guard and action on each transition. Cairn flags states nothing reaches and states with no way out.
Behavior and state machines →Step through fault recovery
Walk a path by hand in the simulator: navigating, a critical fault, the stop. In the rover template, a delivery robot, the only way out of Fault is Fault Cleared, guarded by an operator's acknowledgement and a passed self-test.
Behavior and state machines →Tie safety requirements to tests
Write a safety requirement, such as stopping within half a second of an e-stop, with its acceptance criteria, and plan the test that verifies it. The Trace tool shows each requirement with what satisfies it, what verifies it and its status.
Traceability →
What Cairn doesn't do yet
- Cairn is not a robot simulator. It doesn't read URDF or CAD, and it doesn't generate or run your robot's code.
- There is no shared workspace yet: a project lives in one person's browser and can back up to their account. Others get a copy by export and import.
- Cairn doesn't read or write SysML or ReqIF, and doesn't connect to an issue tracker or PLM.
- Cairn records safety requirements and how they are verified, but it is not a functional-safety or certification tool.
Questions
- Is Cairn a robotics simulator?
- No. It holds the system model: parts, interfaces, modes, requirements and verification. The Behavior lens lets you step through a state machine by hand, to check the modes do what you meant.
- Can each subsystem have its own modes?
- Yes. Every node can have its own state machine: the robot as a whole, the drivetrain, or a single mechanism such as a gripper or a cargo lock.
- Can I bring in an existing robot design?
- Not from other formats: Cairn imports only its own .cairn.zip. Describe the robot in the interview, or build the system tree by hand, and the model grows from there.
See it on your own system.
Describe what you are building and Cairn interviews you, then builds the first model with you.